Conference Deadlines

Conference Deadlines

Deadline shown in your local browser timezone
No deadlines match the current filters.

2026

RadPose: ISAC-based RF 3D Human Pose Estimation

Geo Jie Zhou, KunZhe Song, Ruxin Lin, Huacheng Zeng

The IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2027
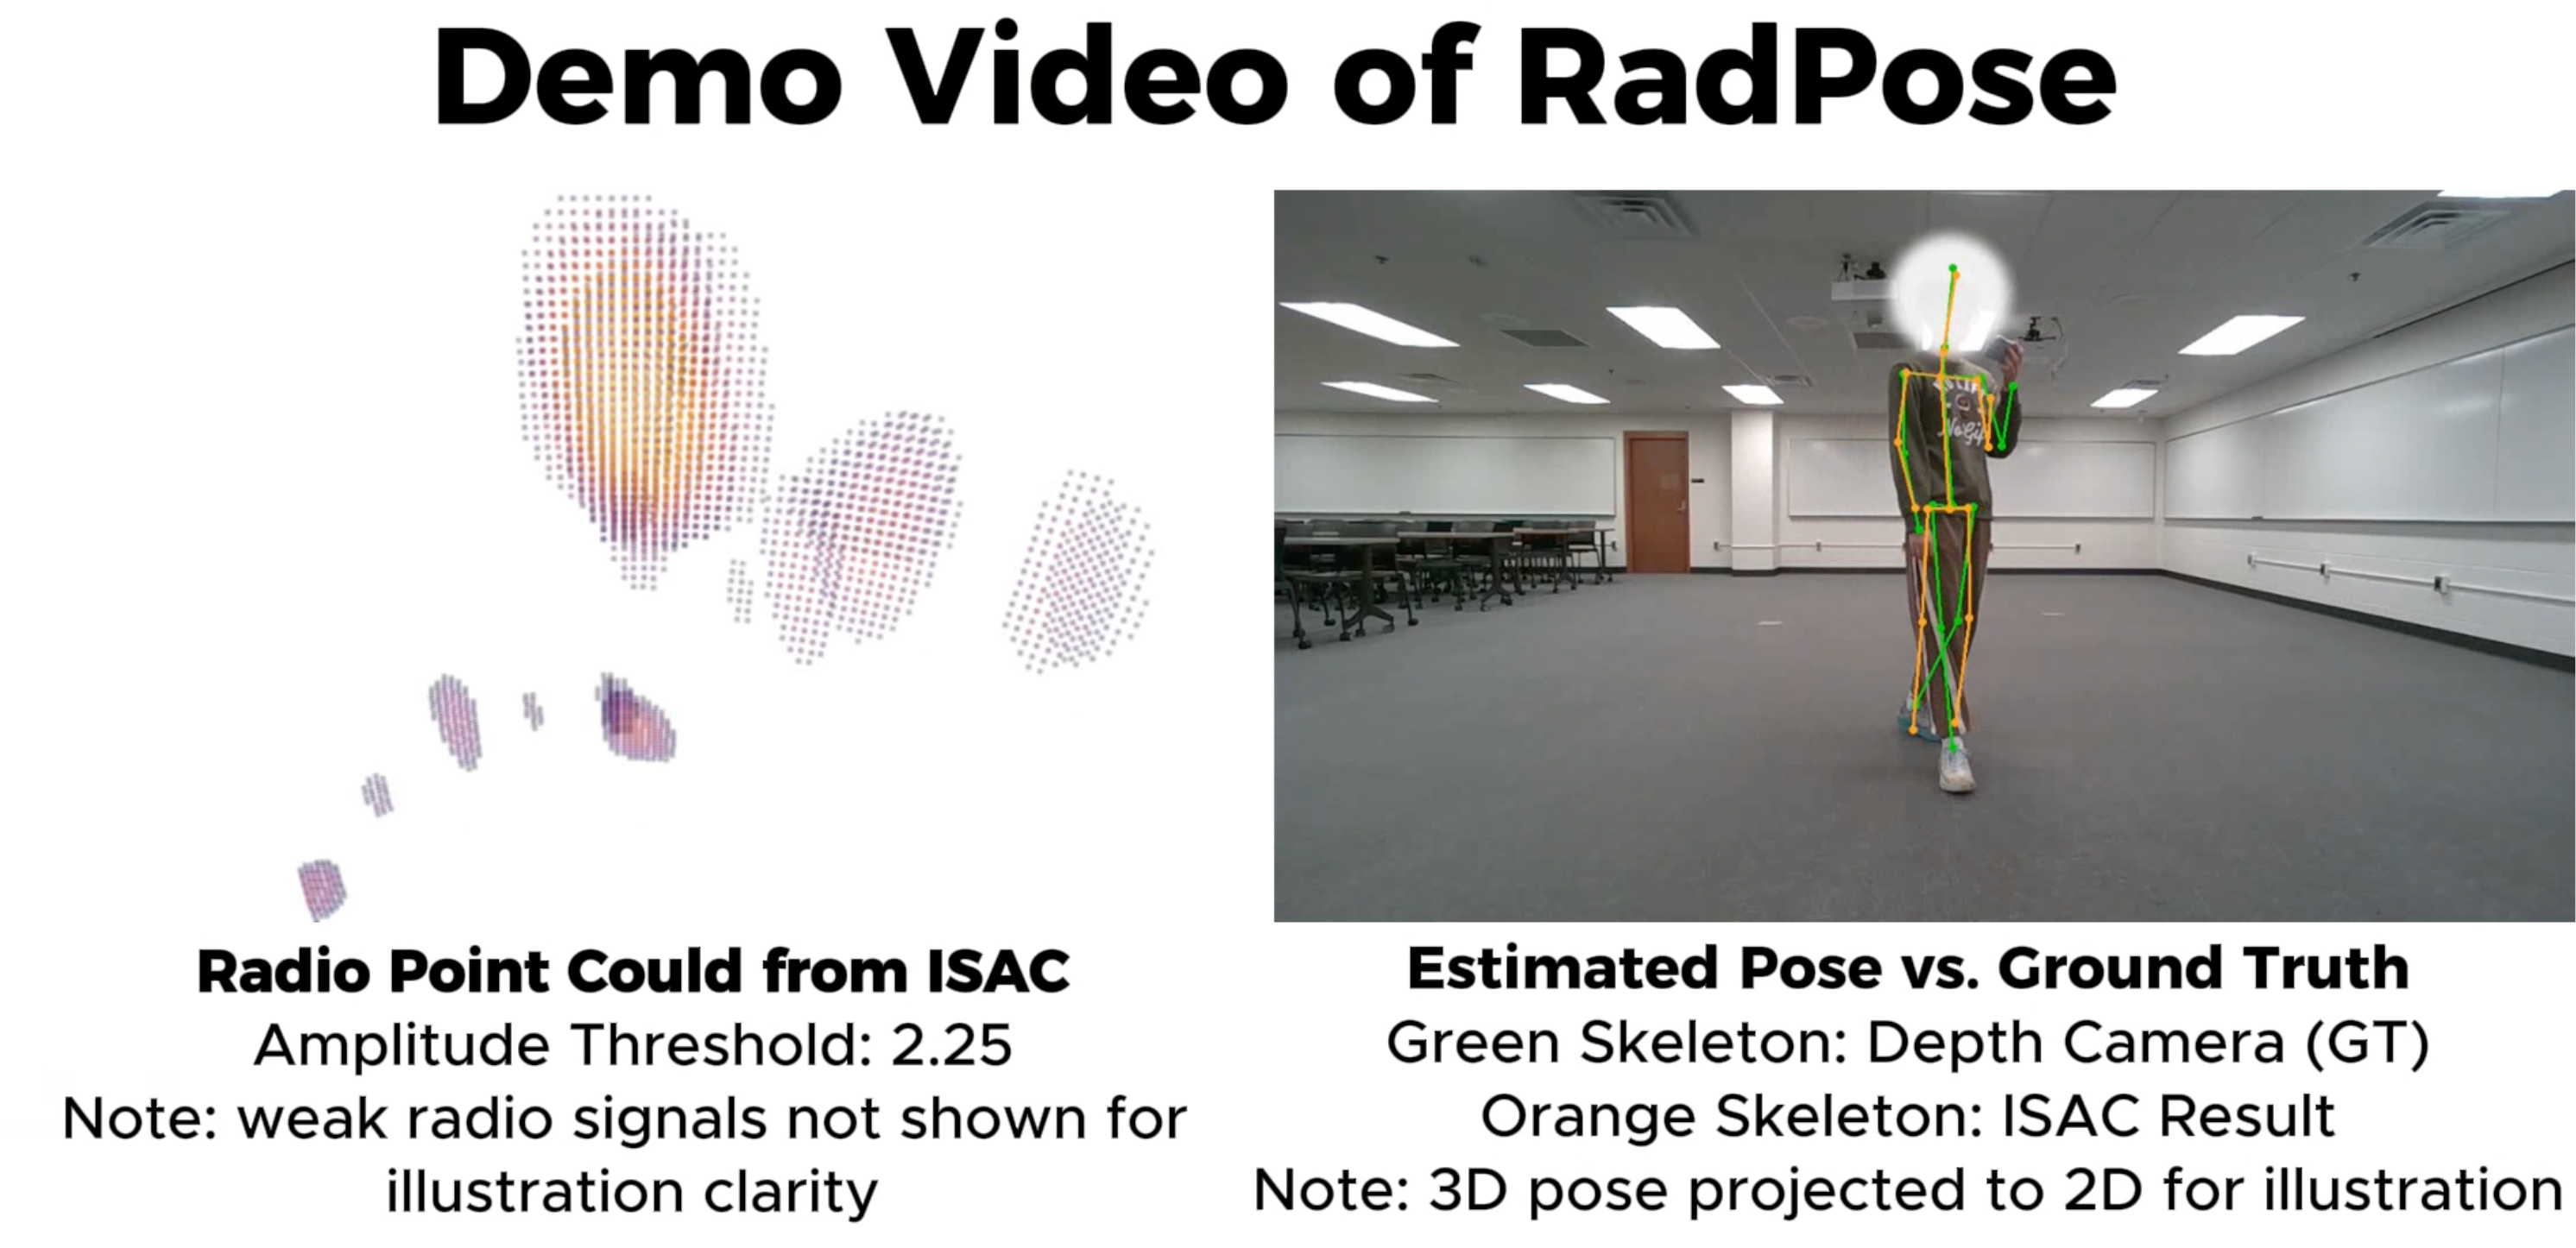
Human pose estimation under adverse lighting and occlusion conditions remains challenging for camera- and LiDAR-based systems. Although mmWave radars provide robustness to illumination and occlusion, they rely on dedicated hardware and licensed spectrum, limiting scalability. In this paper, we present RadPose, a learning-based monostatic integrated sensing and communication (ISAC) framework that enables commodity mmWave communication devices to perform 3D human pose estimation. Unlike specialized radars, RadPose leverages monostatic full-duplex operation to extract channel impulse responses (CIRs) directly from standard OFDM communication signals, generating 3D radio point clouds without additional sensing hardware. To address the sparsity and noise of RF observations, RadPose employs a cross-frame transformer-based pose inference network with semantic-guided spatial attention and target-driven temporal attention for robust spatio-temporal aggregation. It further adopts a joint-aware inverse kinematics refinement module based on graph convolution to enforce skeletal topology, bone-length consistency, and anatomical plausibility. Extensive experiments demonstrate RadPose achieves competitive accuracy compared to state-of-the-art radar-based approaches while maintaining robust performance in unseen and occluded scenarios.

RadPose: ISAC-based RF 3D Human Pose Estimation

Geo Jie Zhou, KunZhe Song, Ruxin Lin, Huacheng Zeng

The IEEE/CVF Winter Conference on Applications of Computer Vision (WACV) 2027

Human pose estimation under adverse lighting and occlusion conditions remains challenging for camera- and LiDAR-based systems. Although mmWave radars provide robustness to illumination and occlusion, they rely on dedicated hardware and licensed spectrum, limiting scalability. In this paper, we present RadPose, a learning-based monostatic integrated sensing and communication (ISAC) framework that enables commodity mmWave communication devices to perform 3D human pose estimation. Unlike specialized radars, RadPose leverages monostatic full-duplex operation to extract channel impulse responses (CIRs) directly from standard OFDM communication signals, generating 3D radio point clouds without additional sensing hardware. To address the sparsity and noise of RF observations, RadPose employs a cross-frame transformer-based pose inference network with semantic-guided spatial attention and target-driven temporal attention for robust spatio-temporal aggregation. It further adopts a joint-aware inverse kinematics refinement module based on graph convolution to enforce skeletal topology, bone-length consistency, and anatomical plausibility. Extensive experiments demonstrate RadPose achieves competitive accuracy compared to state-of-the-art radar-based approaches while maintaining robust performance in unseen and occluded scenarios.

SOPAR: Bee Localization and Tracking Using RF Sub-harmonic Oscillating Parametric Resonator in Hive Environments

Qijun Wang, Peihao Yan, Geo Jie Zhou, Xiang Liu, Dan Stanley, Chunqi Qian, Huacheng Zeng

Proceedings of the ACM on Interactive, Mobile, Wearable and Ubiquitous Technologies (IMWUT) 2026
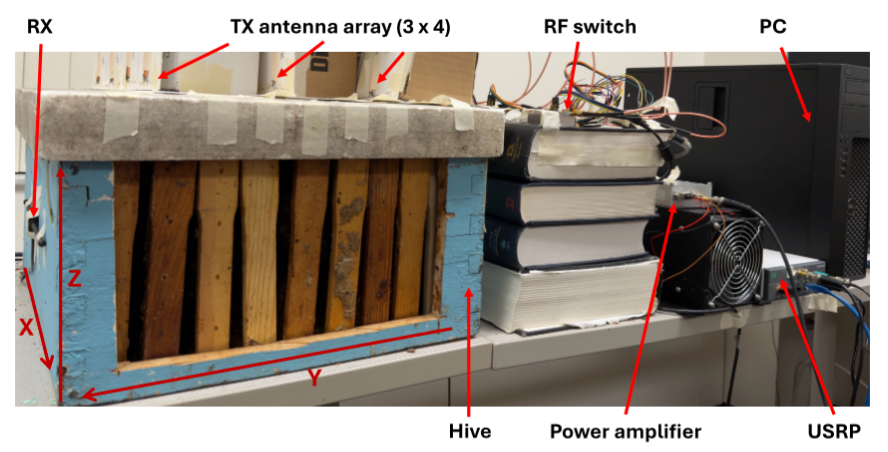
Honey bees play a vital role in global agriculture. Understanding the movement of a queen bee within a hive box is essential for advancing both biological research and practical apiculture. In this paper, we present SOPAR, a novel Radio Frequency (RF) Sub-harmonic Oscillating Parametric Resonator designed for non-invasive localization and tracking of a queen bee inside a full-size hive box. The core component of SOPAR is a lightweight RF backscatter tag that can be attached to a bee's thorax without affecting its normal behavior. The tag comprises two passive resonators: (i) an inner spiral inductor bridged by a varactor diode and (ii) an outer circular inductor with a gap bridged by a chip capacitor. The outer inductor harvests energy from the external excitation signal, driving the oscillation of the inner spiral resonator to produce sub-harmonic backscattered signals at half the excitation frequency. The frequency separation between excitation and backscatter signals eliminates self-interference at the RF reader, significantly improving signal-to-noise ratio (SNR) and detection range. The layout of the two resonators is meticulously optimized to maximize magnetic coupling, thereby minimizing the overall tag size. Building on this dual-resonator tag, we design an RF reader with a Bayesian estimation algorithm that localizes the tagged bee by exploiting the spatio-temporal characteristics of the sub-harmonic backscattered signals. We have built a prototype of SOPAR, featuring a tag with a diameter of only 3.7 mm and a weight of less than 10 mg. Extensive experiments demonstrate that SOPAR achieves a median localization error of 3.7 cm when tracking a queen bee in a full-size hive box. Moreover, the results confirm that SOPAR remains robust under diverse environmental conditions.

SOPAR: Bee Localization and Tracking Using RF Sub-harmonic Oscillating Parametric Resonator in Hive Environments

Qijun Wang, Peihao Yan, Geo Jie Zhou, Xiang Liu, Dan Stanley, Chunqi Qian, Huacheng Zeng

Proceedings of the ACM on Interactive, Mobile, Wearable and Ubiquitous Technologies (IMWUT) 2026

Honey bees play a vital role in global agriculture. Understanding the movement of a queen bee within a hive box is essential for advancing both biological research and practical apiculture. In this paper, we present SOPAR, a novel Radio Frequency (RF) Sub-harmonic Oscillating Parametric Resonator designed for non-invasive localization and tracking of a queen bee inside a full-size hive box. The core component of SOPAR is a lightweight RF backscatter tag that can be attached to a bee's thorax without affecting its normal behavior. The tag comprises two passive resonators: (i) an inner spiral inductor bridged by a varactor diode and (ii) an outer circular inductor with a gap bridged by a chip capacitor. The outer inductor harvests energy from the external excitation signal, driving the oscillation of the inner spiral resonator to produce sub-harmonic backscattered signals at half the excitation frequency. The frequency separation between excitation and backscatter signals eliminates self-interference at the RF reader, significantly improving signal-to-noise ratio (SNR) and detection range. The layout of the two resonators is meticulously optimized to maximize magnetic coupling, thereby minimizing the overall tag size. Building on this dual-resonator tag, we design an RF reader with a Bayesian estimation algorithm that localizes the tagged bee by exploiting the spatio-temporal characteristics of the sub-harmonic backscattered signals. We have built a prototype of SOPAR, featuring a tag with a diameter of only 3.7 mm and a weight of less than 10 mg. Extensive experiments demonstrate that SOPAR achieves a median localization error of 3.7 cm when tracking a queen bee in a full-size hive box. Moreover, the results confirm that SOPAR remains robust under diverse environmental conditions.

Rascene: High-Fidelity 3D Scene Imaging with mmWave Communication Signals

KunZhe Song, Geo Jie Zhou, Xiaoming Liu, Huacheng Zeng

The IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR) 2026

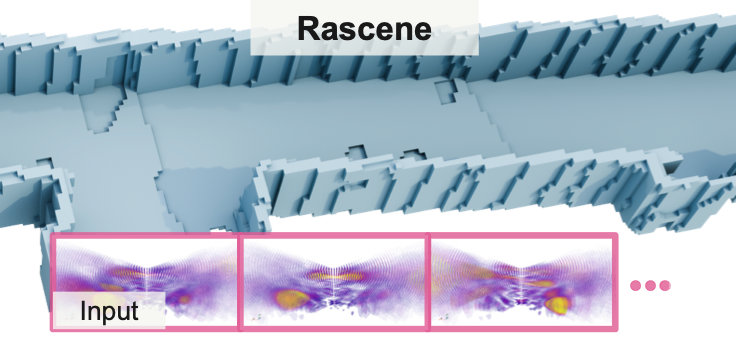
Robust 3D environmental perception is critical for applications like autonomous navigation and robotics, yet existing optical sensors like cameras and LiDAR fail in adverse conditions such as smoke, fog, and non-ideal lighting. While specialized radar systems can operate in these conditions, their reliance on bespoke, ultra-wideband hardware and licensed spectrum limits their scalability and cost-effectiveness. This paper introduces Rascene, a novel framework that enables high-fidelity 3D imaging by repurposing ubiquitous mmWave OFDM communication signals. Recognizing that a single-frame RF signal is inherently sparse, noisy, and highly ambiguous, the key innovation of Rascene is a multi-frame 3D imaging framework designed to fuse information from signals captured across multiple, arbitrary poses. This framework leverages a spatially adaptive fusion mechanism to find geometric consensus across the multiple views, effectively suppressing multipath artifacts while preserving sparse geometric details. Experiments demonstrate that our method reconstructs 3D scenes with high precision, providing a new pathway for low-cost, scalable, and robust 3D perception.